
How do we teach a robot to pick up an object?
The traditional approach is to program the robot step by step.
But as the number of tasks increases and environments become more complex, it becomes increasingly difficult to define every possible situation in advance.
There is another approach:
Let robots learn from the way humans perform tasks.
This is also the goal of the Human Demonstration Data service that Saltlux Technology provides for Physical AI and Robotics applications.
Capturing How Humans Perform a Task
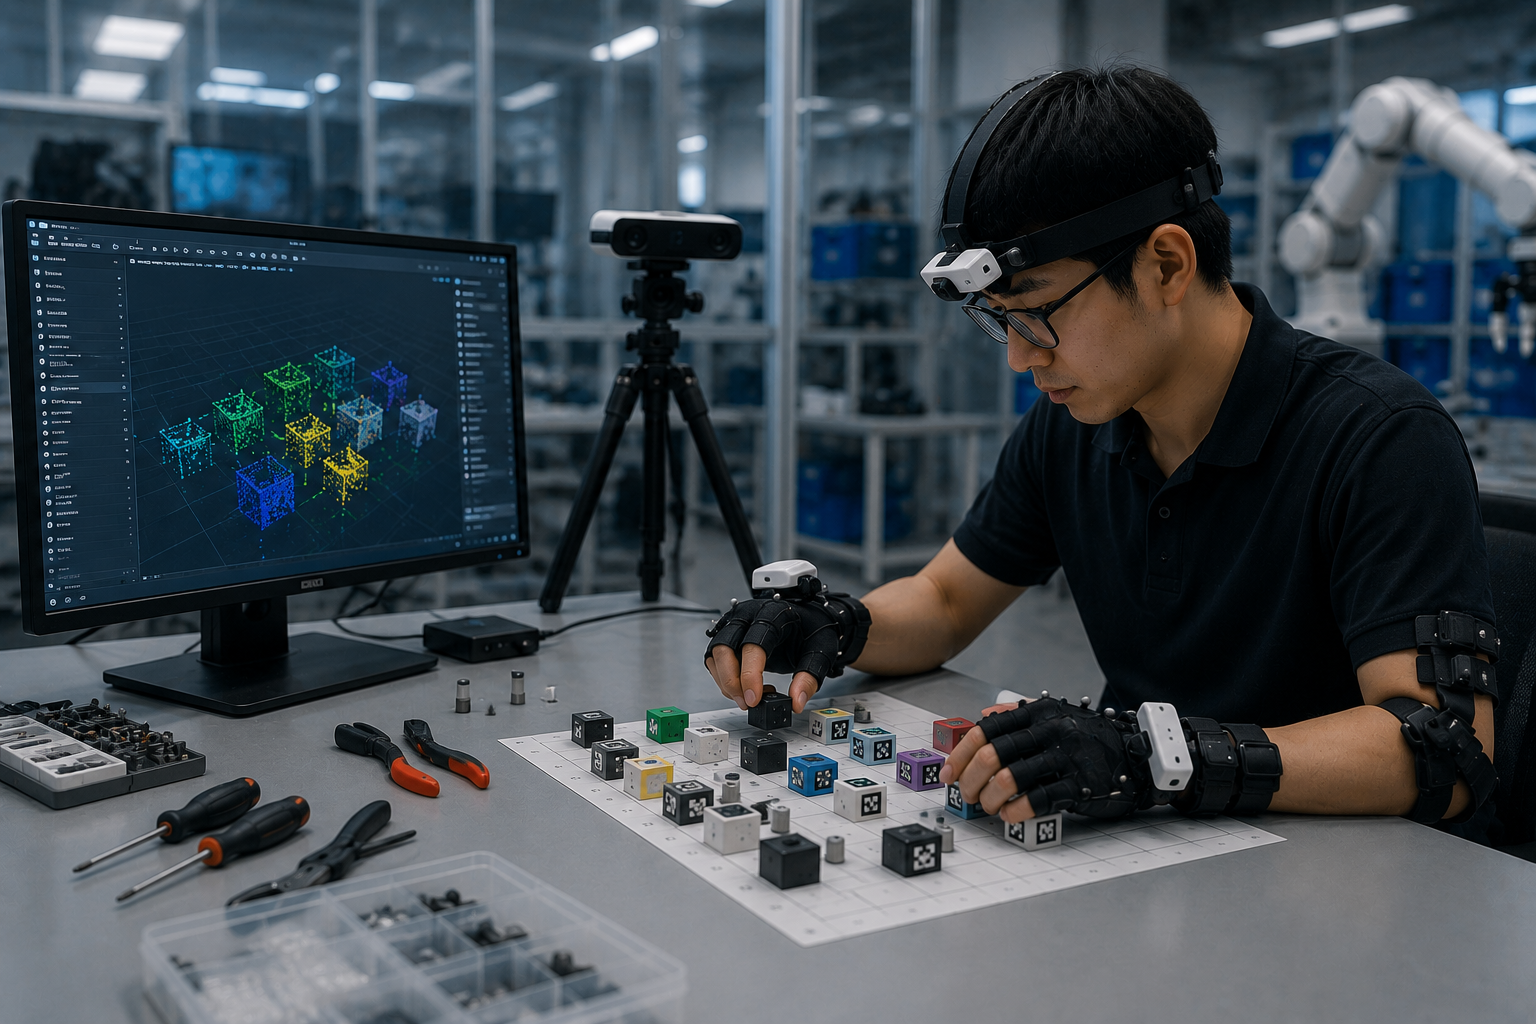
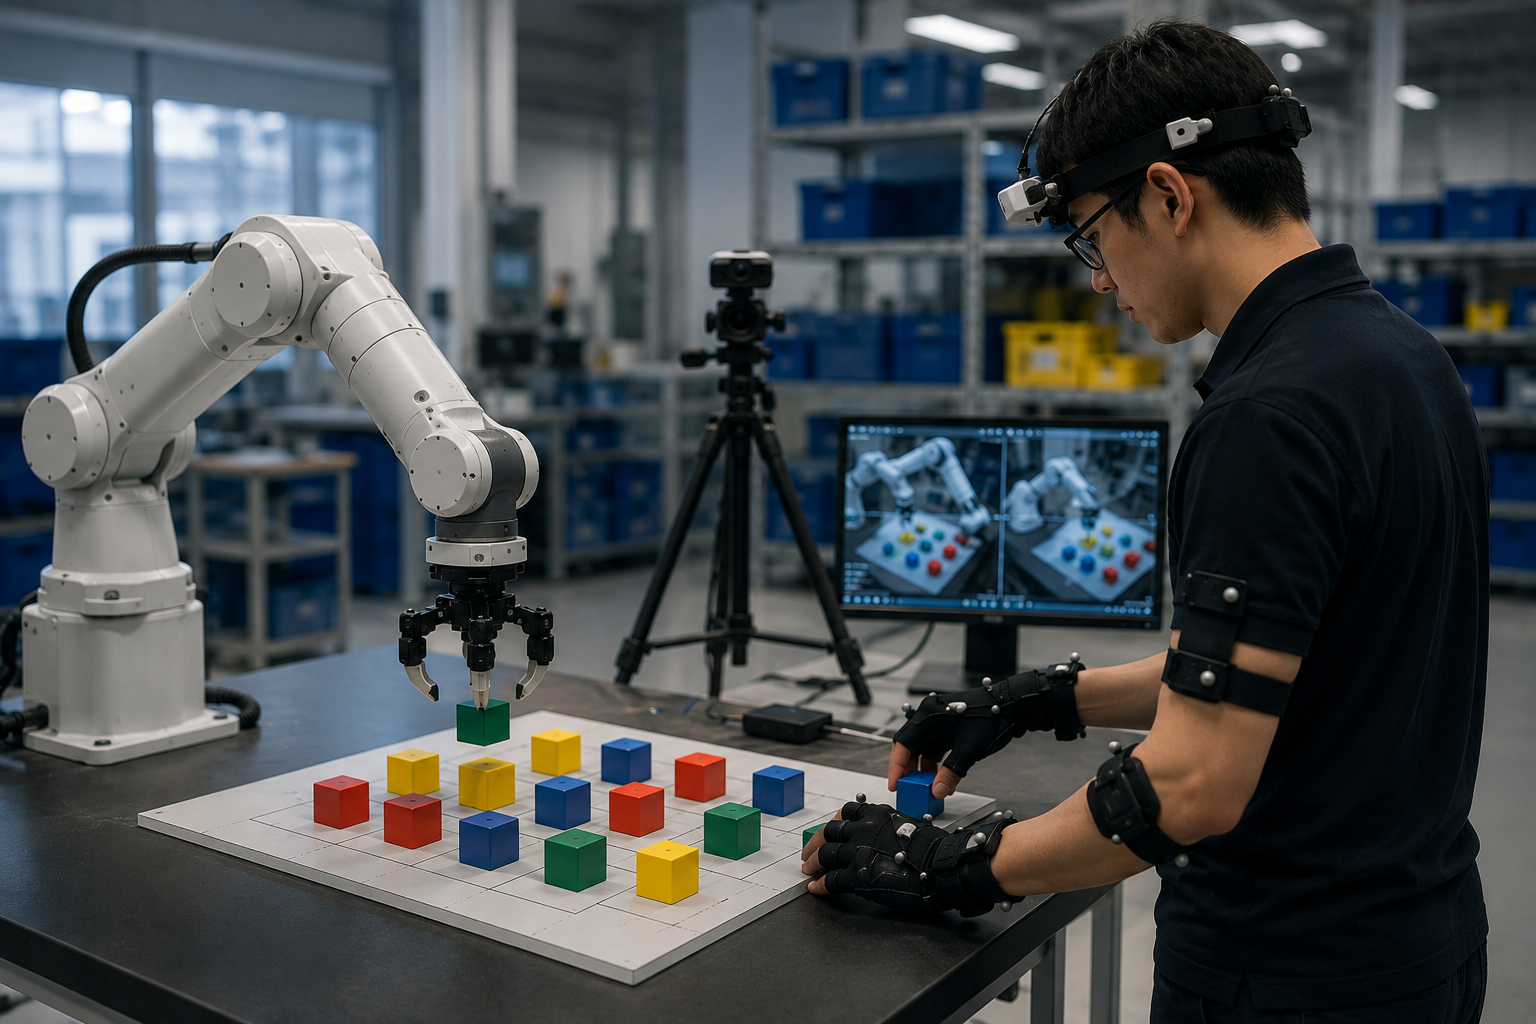
During the data collection process, participants are equipped with data capture devices and asked to perform predefined tasks and scenarios.
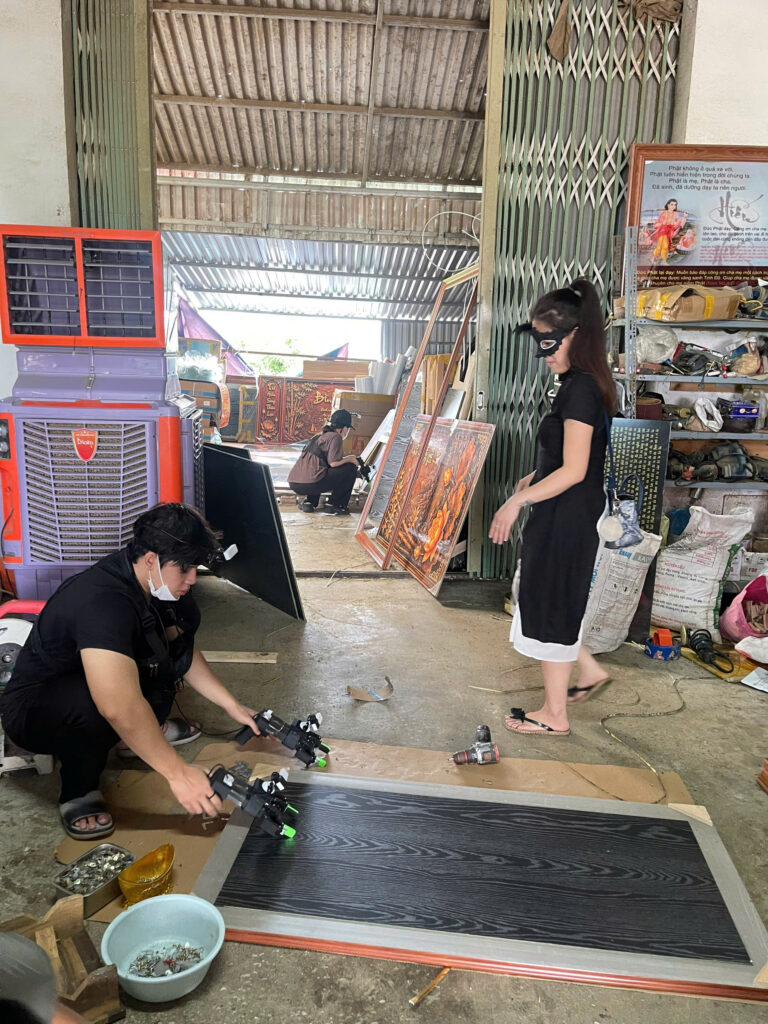
Instead of simply recording a person picking up a product from a shelf, the goal is to capture the entire sequence of interaction:
Observe → Reach → Grasp → Move → Place
This is known as a Human Demonstration—a real-world example of how a human completes a particular task.
Controlled Data Collection in the Lab
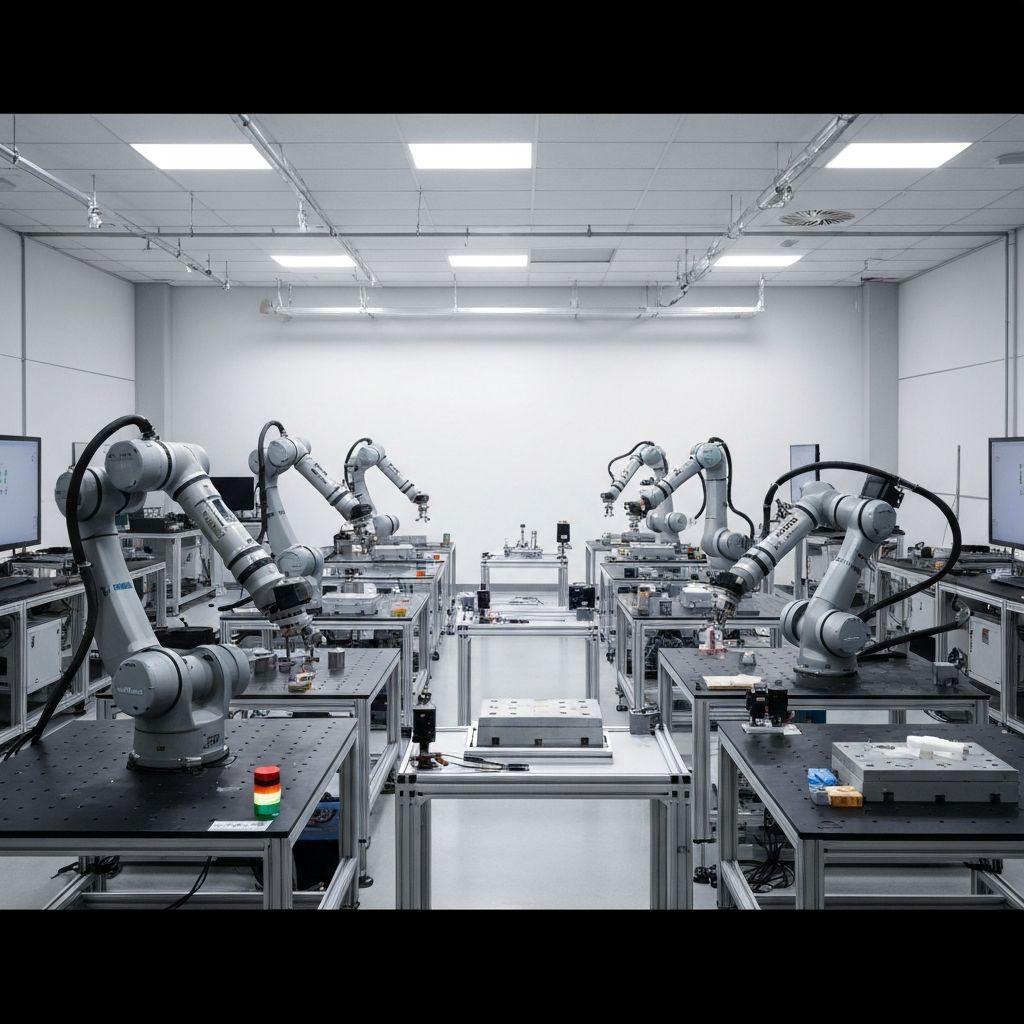
The Lab plays an important role in this process.
Within a controlled environment, the same task can be performed repeatedly while intentionally varying different conditions.
For example:
Objects can be placed in different positions; objects of different sizes can be used; grasping methods can be changed; the sequence of actions can be varied; or a task can be performed using both hands.
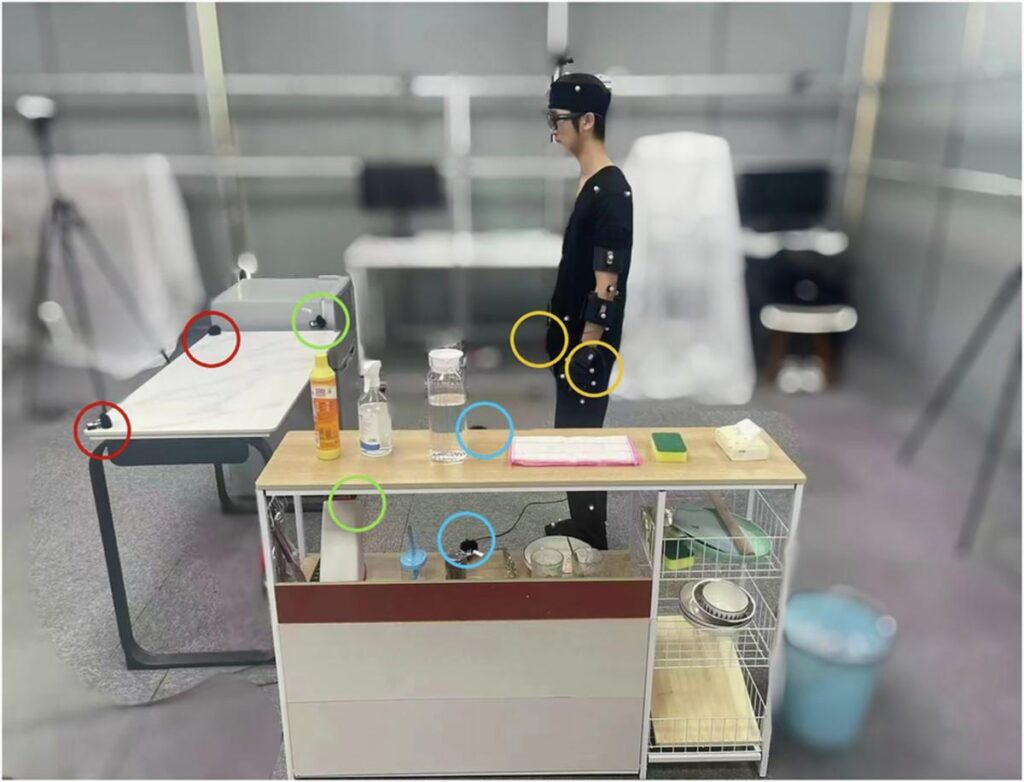
This allows our team to systematically control different variables and build datasets tailored to the requirements of each specific use case.
From the Lab to Real-World Scenarios
The next step is to bring data collection into real-world environments.
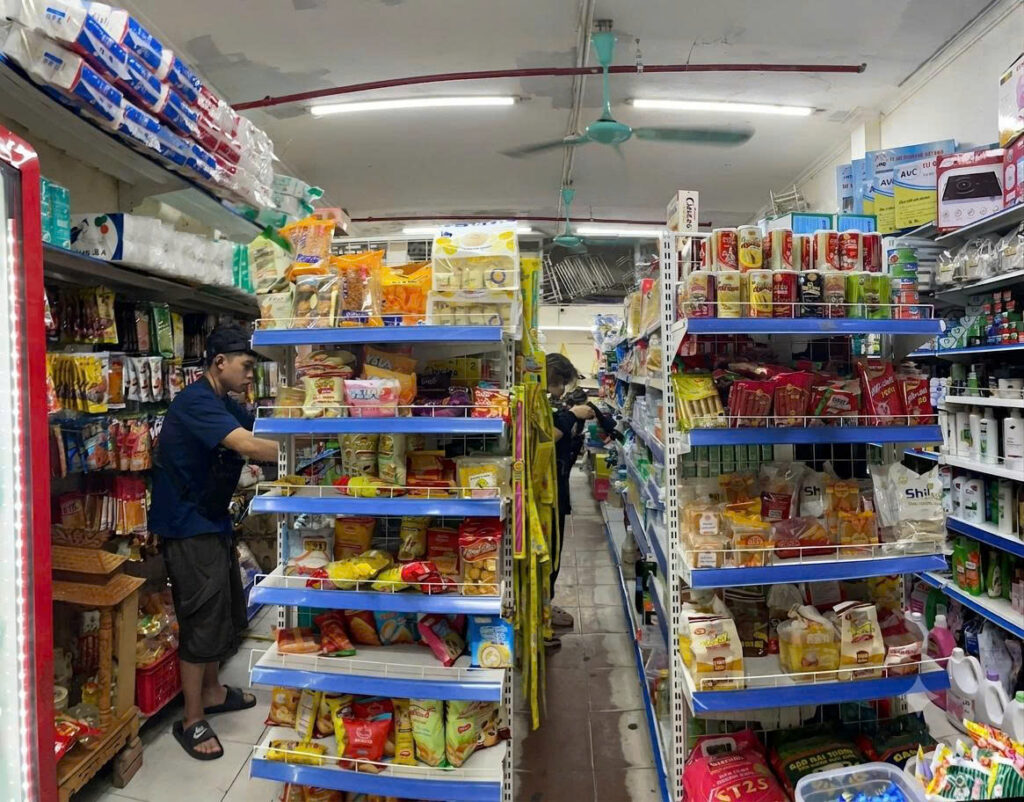
In a retail environment, participants may need to interact with a wide variety of products.
In factories and workshops, tasks may involve materials, tools, machinery, and other equipment.
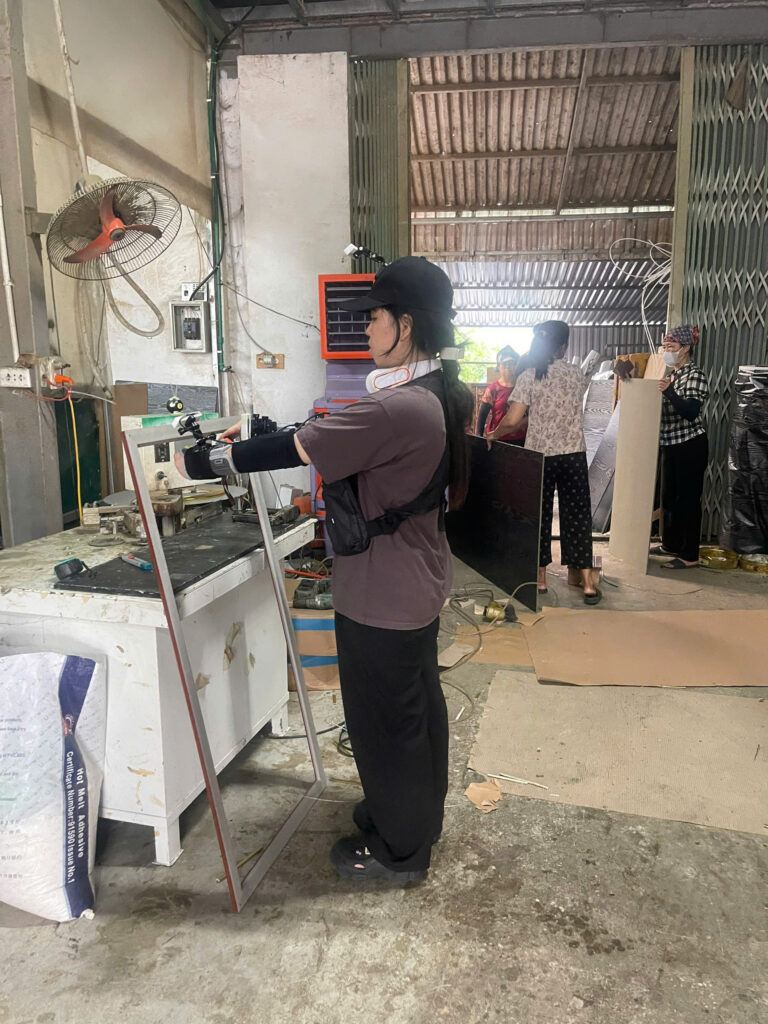
Some tasks also require both hands to work together. In robotics, this is commonly known as bimanual manipulation.
Such data is particularly valuable for research and development of robots designed to perform increasingly complex tasks in ways that more closely resemble human behavior.
Data for Robot Learning
After collection and processing, Human Demonstration Data can serve as a valuable data source for areas such as:
Imitation Learning – enabling robots to learn by imitating demonstrations;
Robot Learning – helping robots learn how to perform tasks from data;
Embodied / Physical AI – enabling AI systems to perceive, understand, and act in the physical world.
Saltlux Technology’s Human Demonstration Data service focuses on a critical part of this process: Transforming real-world human actions into data that AI and robots can learn from.